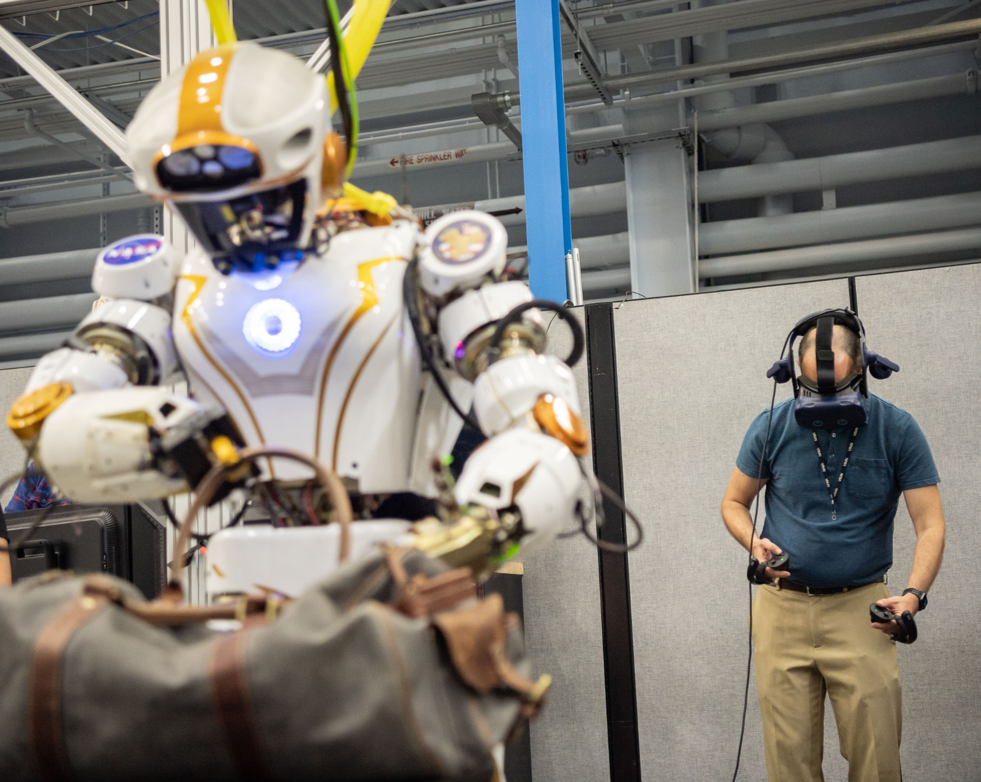
The idea of humans and robots working side-by-side in space was once the stuff of science fiction, but with NASA launching increasingly complex missions deeper into space, human-robot collaboration could become reality.
Advanced robotic systems are critical for human spaceflight because they can enhance a crew’s performance and productivity while reducing risk and expanding the capabilities for space exploration. The Dexterous Robotics Team at NASA’s Johnson Space Center in Houston plays a key role in developing robotic hardware and software to support NASA’s bold vision for the future, with a focus on robots that can complete tasks humans do with their hands.
“Our team is not trying to replace human explorers with robots but instead make human exploration safer and more sustainable by developing highly capable, reliable, and trustworthy robots to work in extreme environments,” said Shaun Azimi, Dexterous Robotics Team lead. “If we can send more capable robots, we can reduce the risk and make people more effective in doing the things that people do best.”
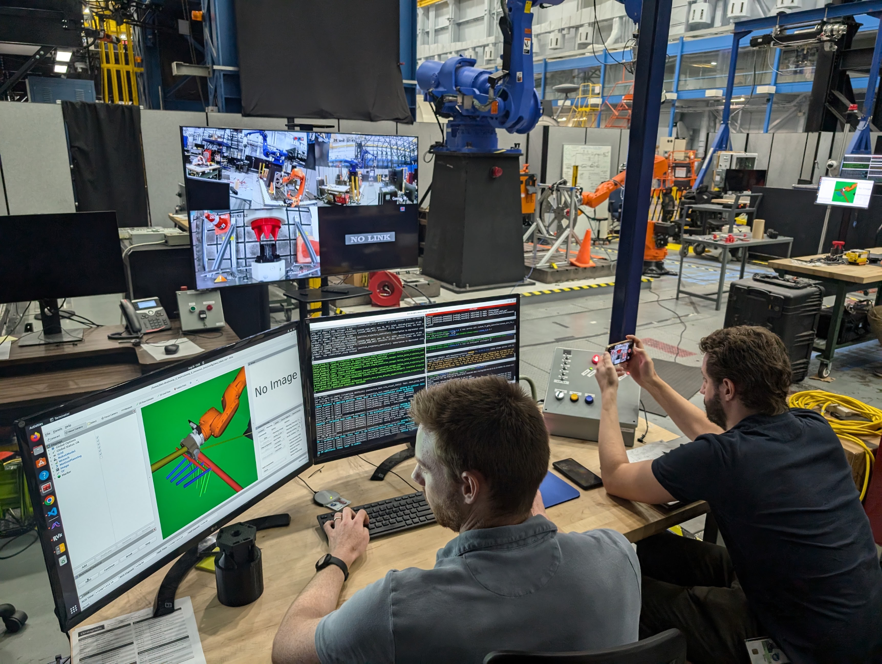
The 16-member team is part of NASA’s Robotic System Technology Branch, which also develops mobility systems like unmanned planetary rovers. Azimi is one of several engineers who work on both dexterity and mobility projects. There is also crossover within the Dexterous Robotics Team. While the group is generally organized into two subgroups, mechatronics and software, most team members have experience in electronics or mechanics as well as writing software for simulations or analyses.
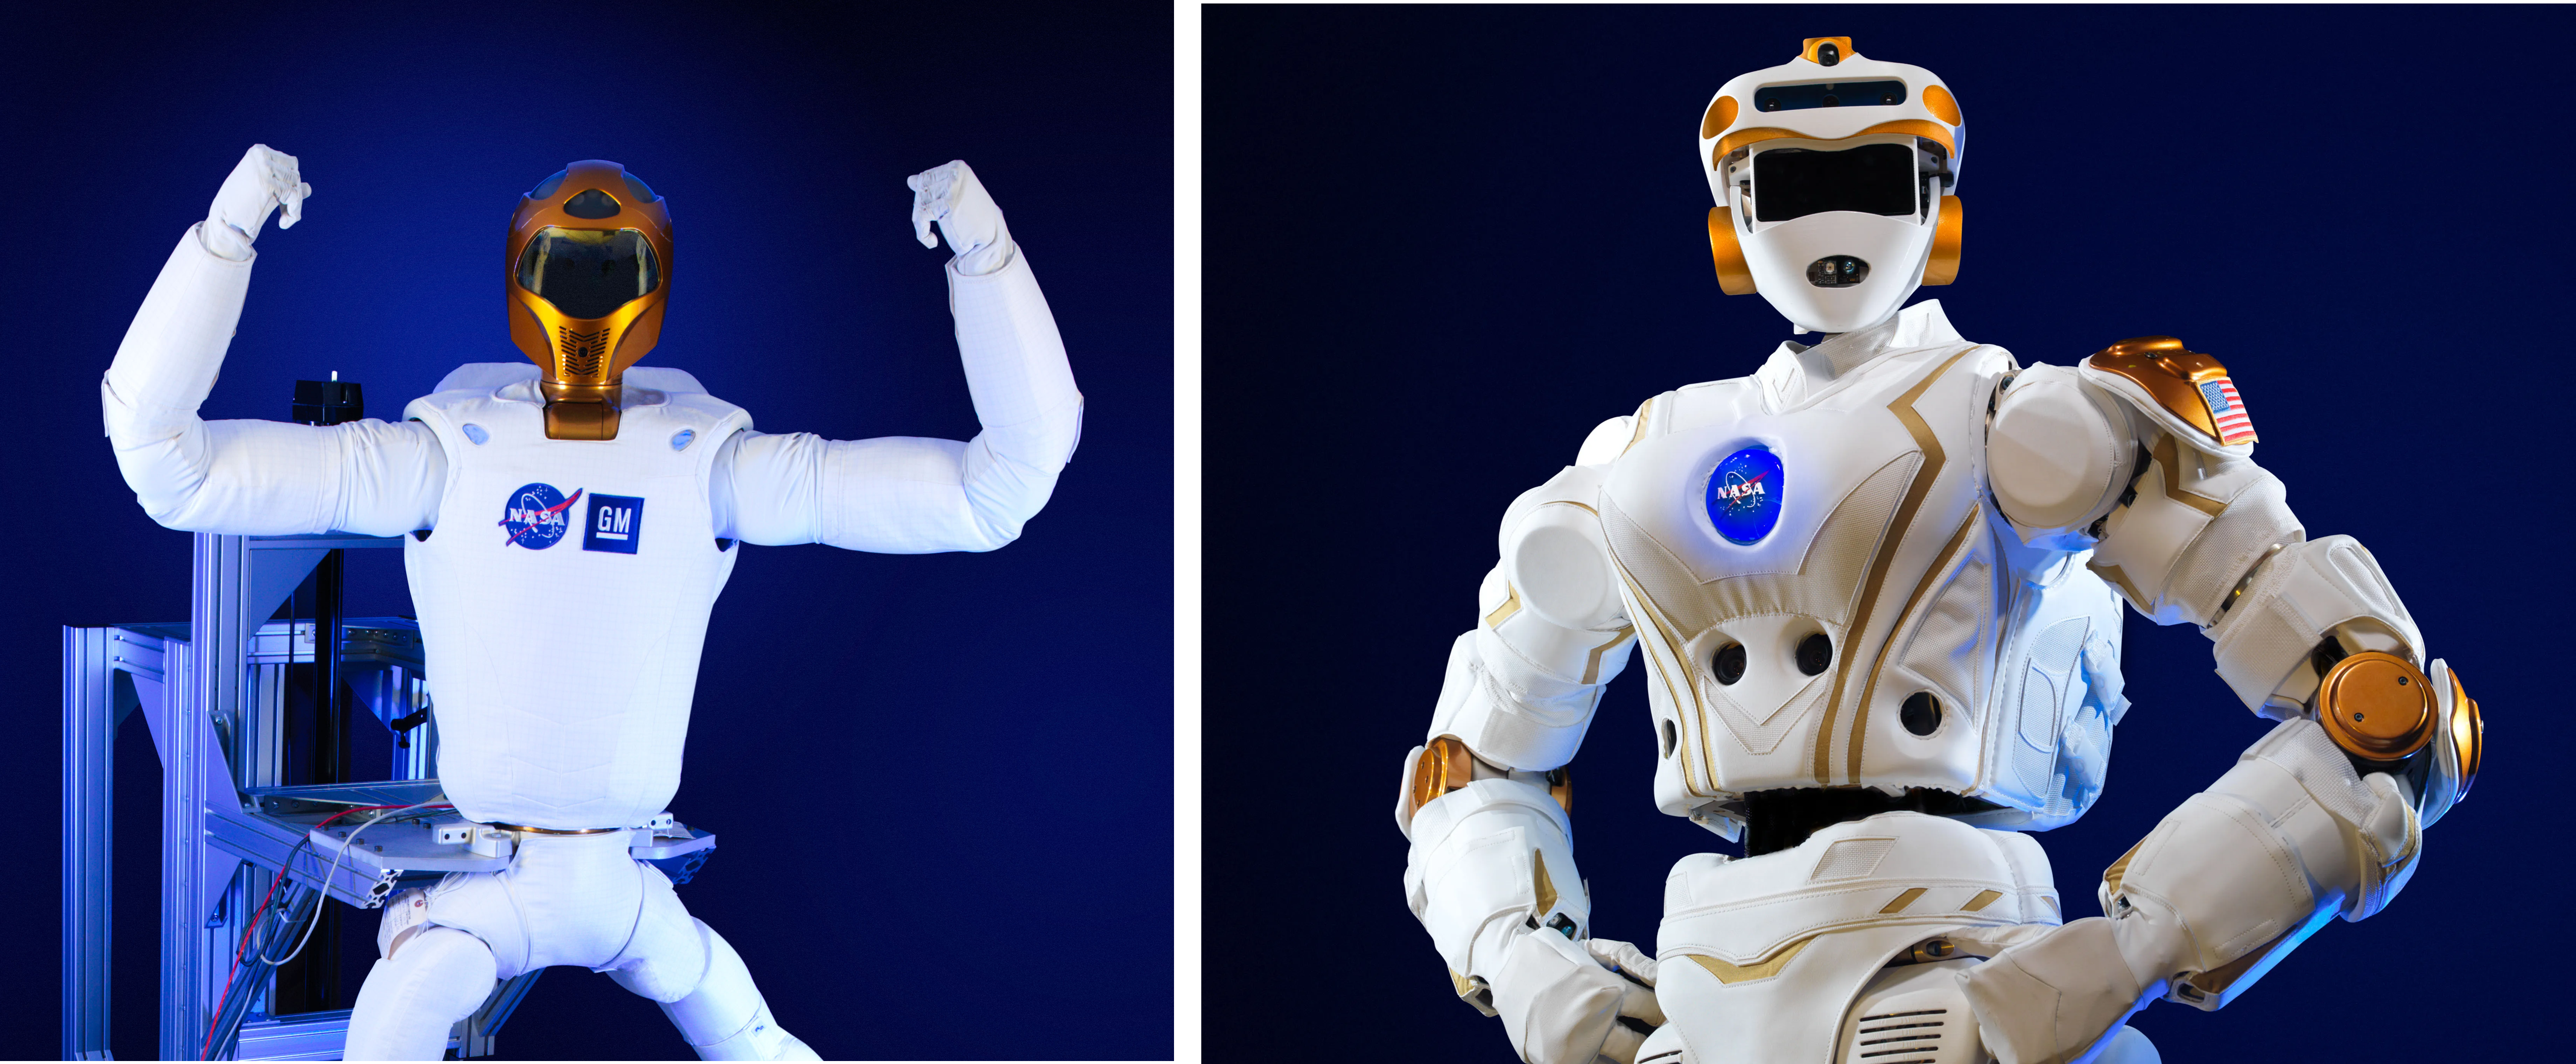
Much of that experience was gained by working on two well-known humanoid robots – the Robonaut 2, which participated in robotics technology demonstrations aboard the International Space Station for seven years, and Valkyrie, NASA’s first bipedal humanoid robot. Many of the employees who worked on those projects now make up the Dexterous Robotics Team and continue to build upon the robots’ legacy.
Today the team supports a variety of agency projects and programs, some of which are exploring connections to building the Moon Base, humanity’s first lunar outpost. “Our work is a combination of technology research and development, and applied technology on the operational side,” Azimi said. The team also collaborates with private industry and other external partners that face similar challenges in their work, such as an oil and gas company seeking to leverage robotic technologies in harsh environments and for riskier tasks.
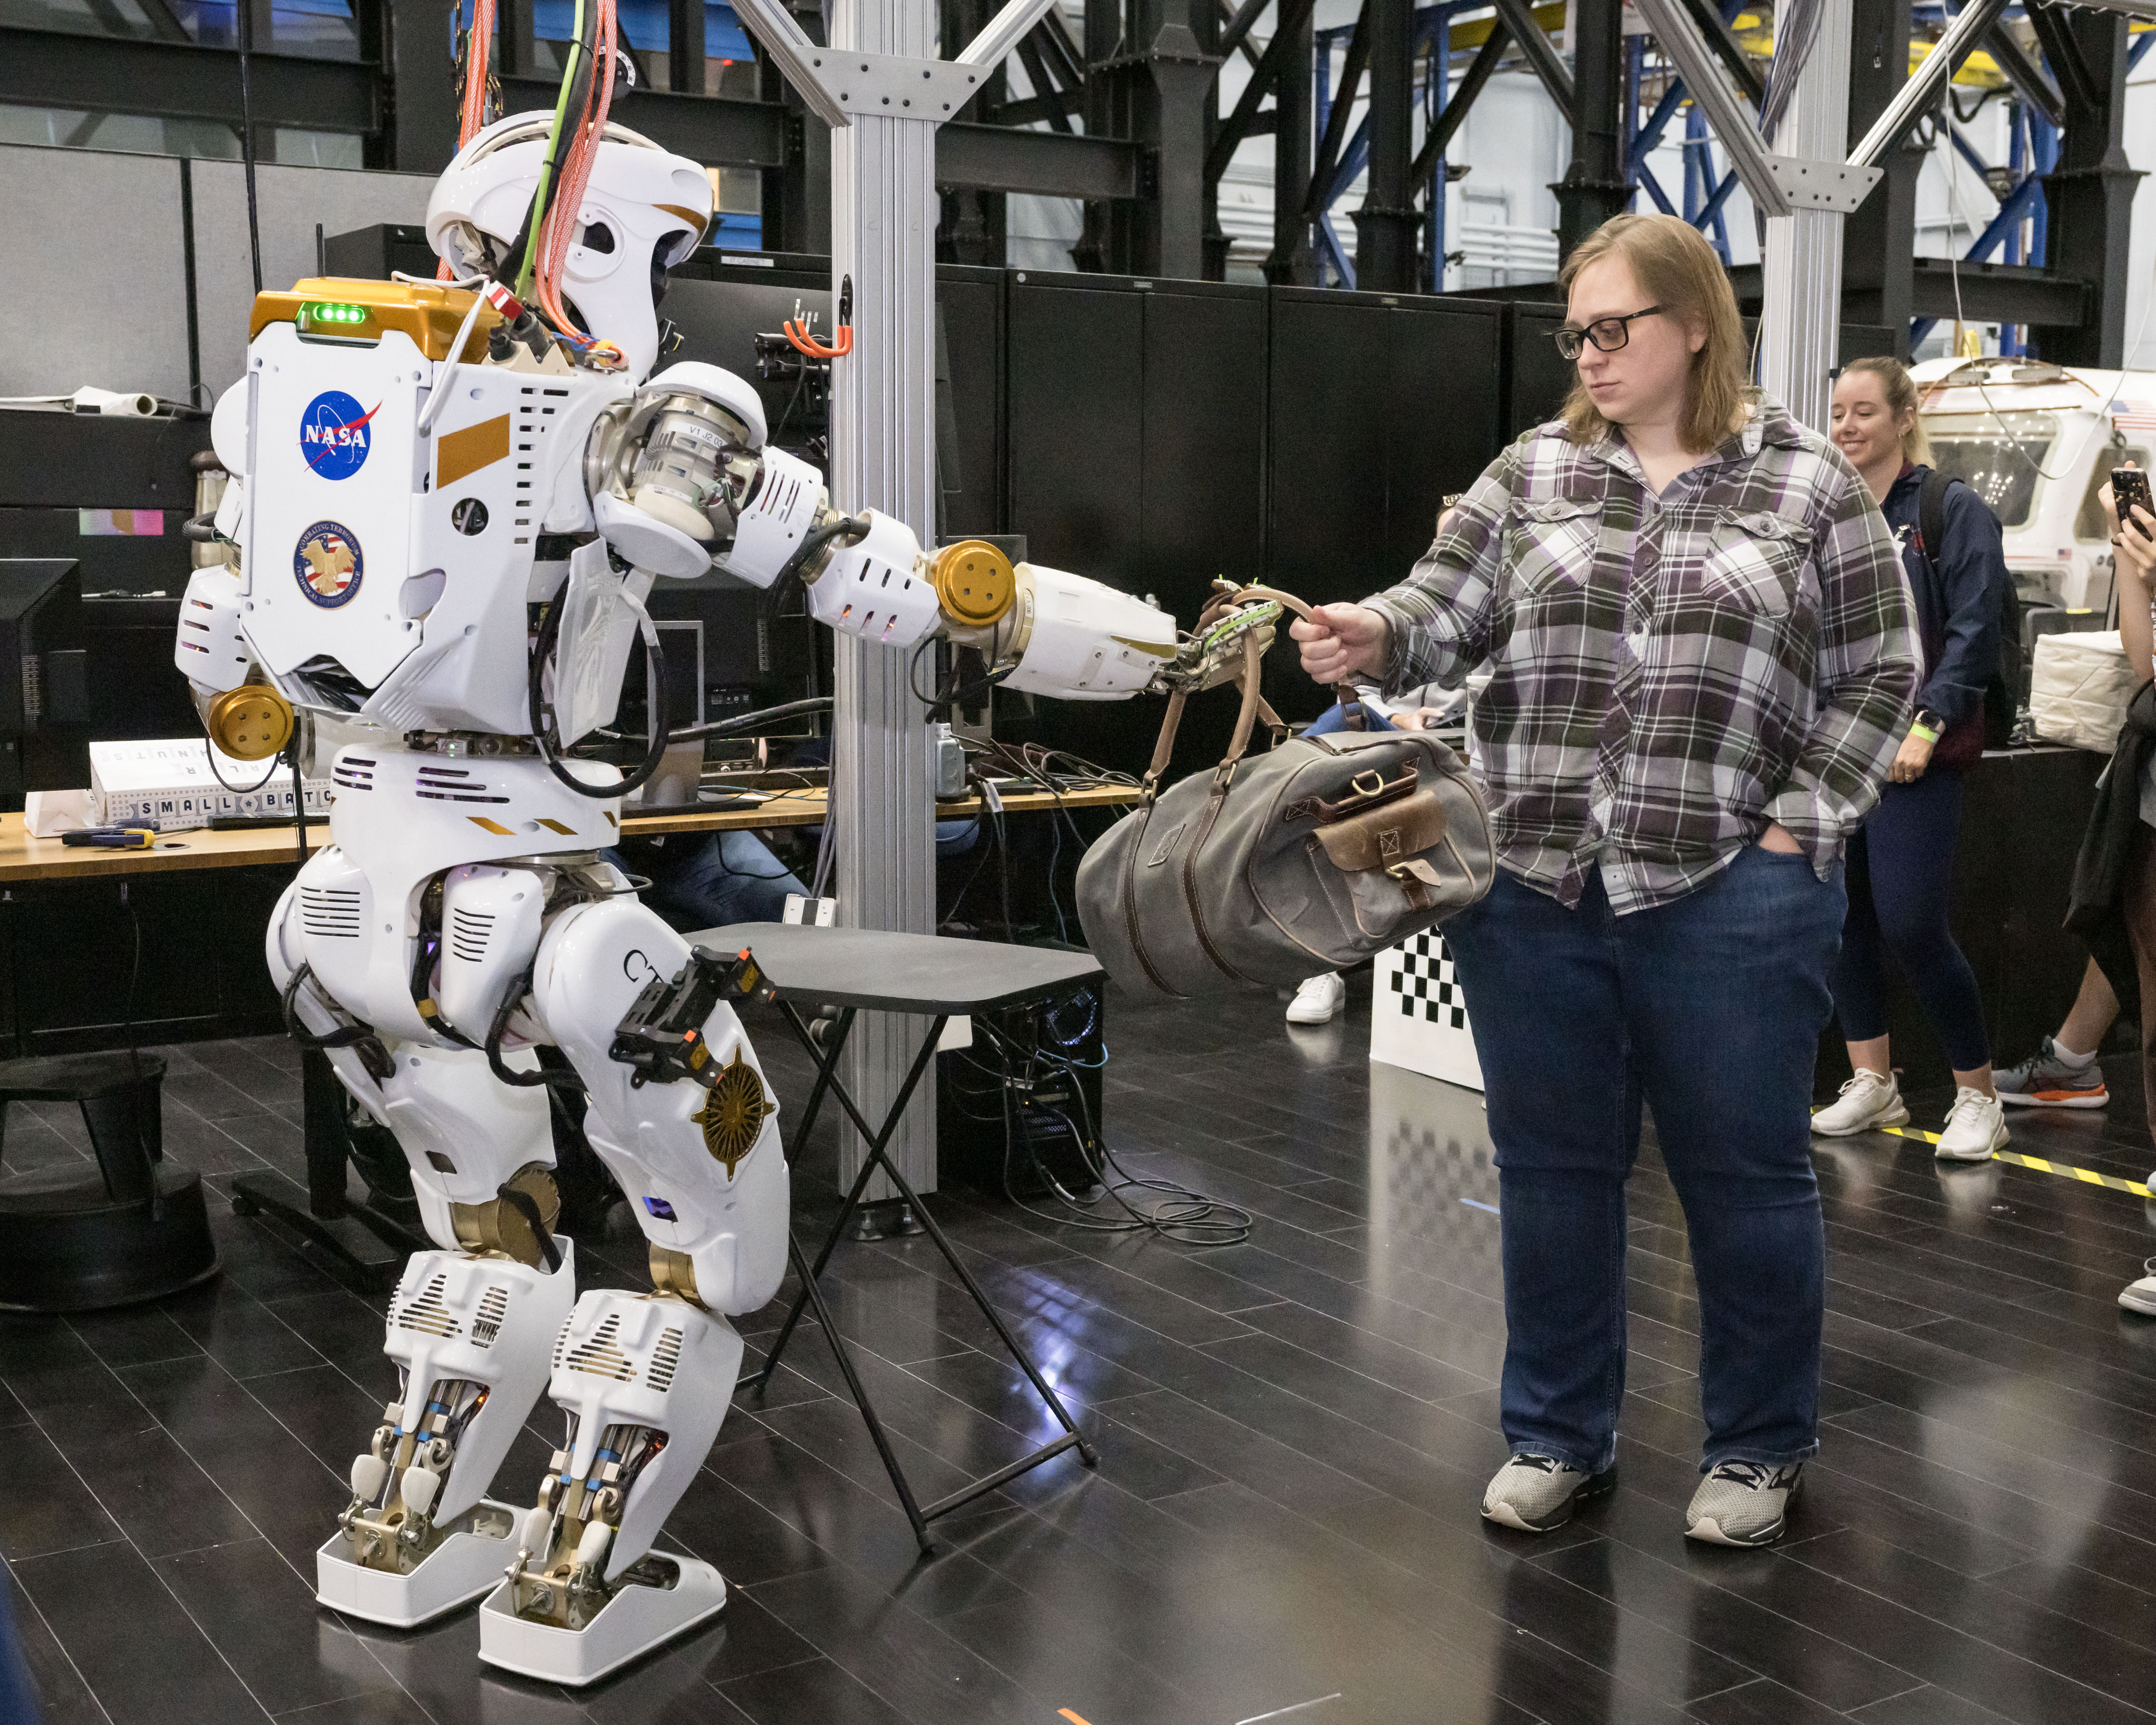
A major focus for the team has been development of the Integrated Mobile Evaluation Testbed for Robotics Operations (iMETRO) facility at Johnson. Available to NASA programs and external partners, iMETRO is designed to support the adaptation of terrestrial robotic technologies for human-supervised space exploration applications such as logistics, maintenance, and scientific research. The facility comprises open-source software and simulation assets, as well as space vehicle and habitat mockups, a selection of “house robots,” and an outdoor rock yard. Offering digital and physical facilities gives iMETRO users the flexibility to test a whole robot or a single hardware or software component.
Azimi said iMETRO helps remove the guesswork from NASA’s collaboration with external partners. “It shows them the things we actually need done so they don’t have to speculate,” he said. “We can also bring together the people who are developing the robotic technologies – hardware, software, or both – with the people who are actually designing a lunar surface habitat or rover.” This enables different teams to learn from each other: The technology providers gain a better understanding of the habitat, while the habitat designers learn what features are needed to accommodate a robot. “They can learn about how robots perceive the world and interact with objects, and what is difficult for a robot compared to a human,” Azimi said. “It’s not necessarily a totally different interface, and something like a bigger handle or better lighting might make things easier for a person as well.”
In one case, a team from PickNik Inc. used iMETRO to test software enabling a robotic arm to recognize a spacecraft hatch, then turn the latch, grasp the handle, and open the door. The arm was then able to transfer cargo bags between the hatch and a bin. The facility also supported a NASA intern’s development and testing of software that used a common commercial robotic arm and camera to inspect and maintain a cold stowage freezer like those aboard the space station.
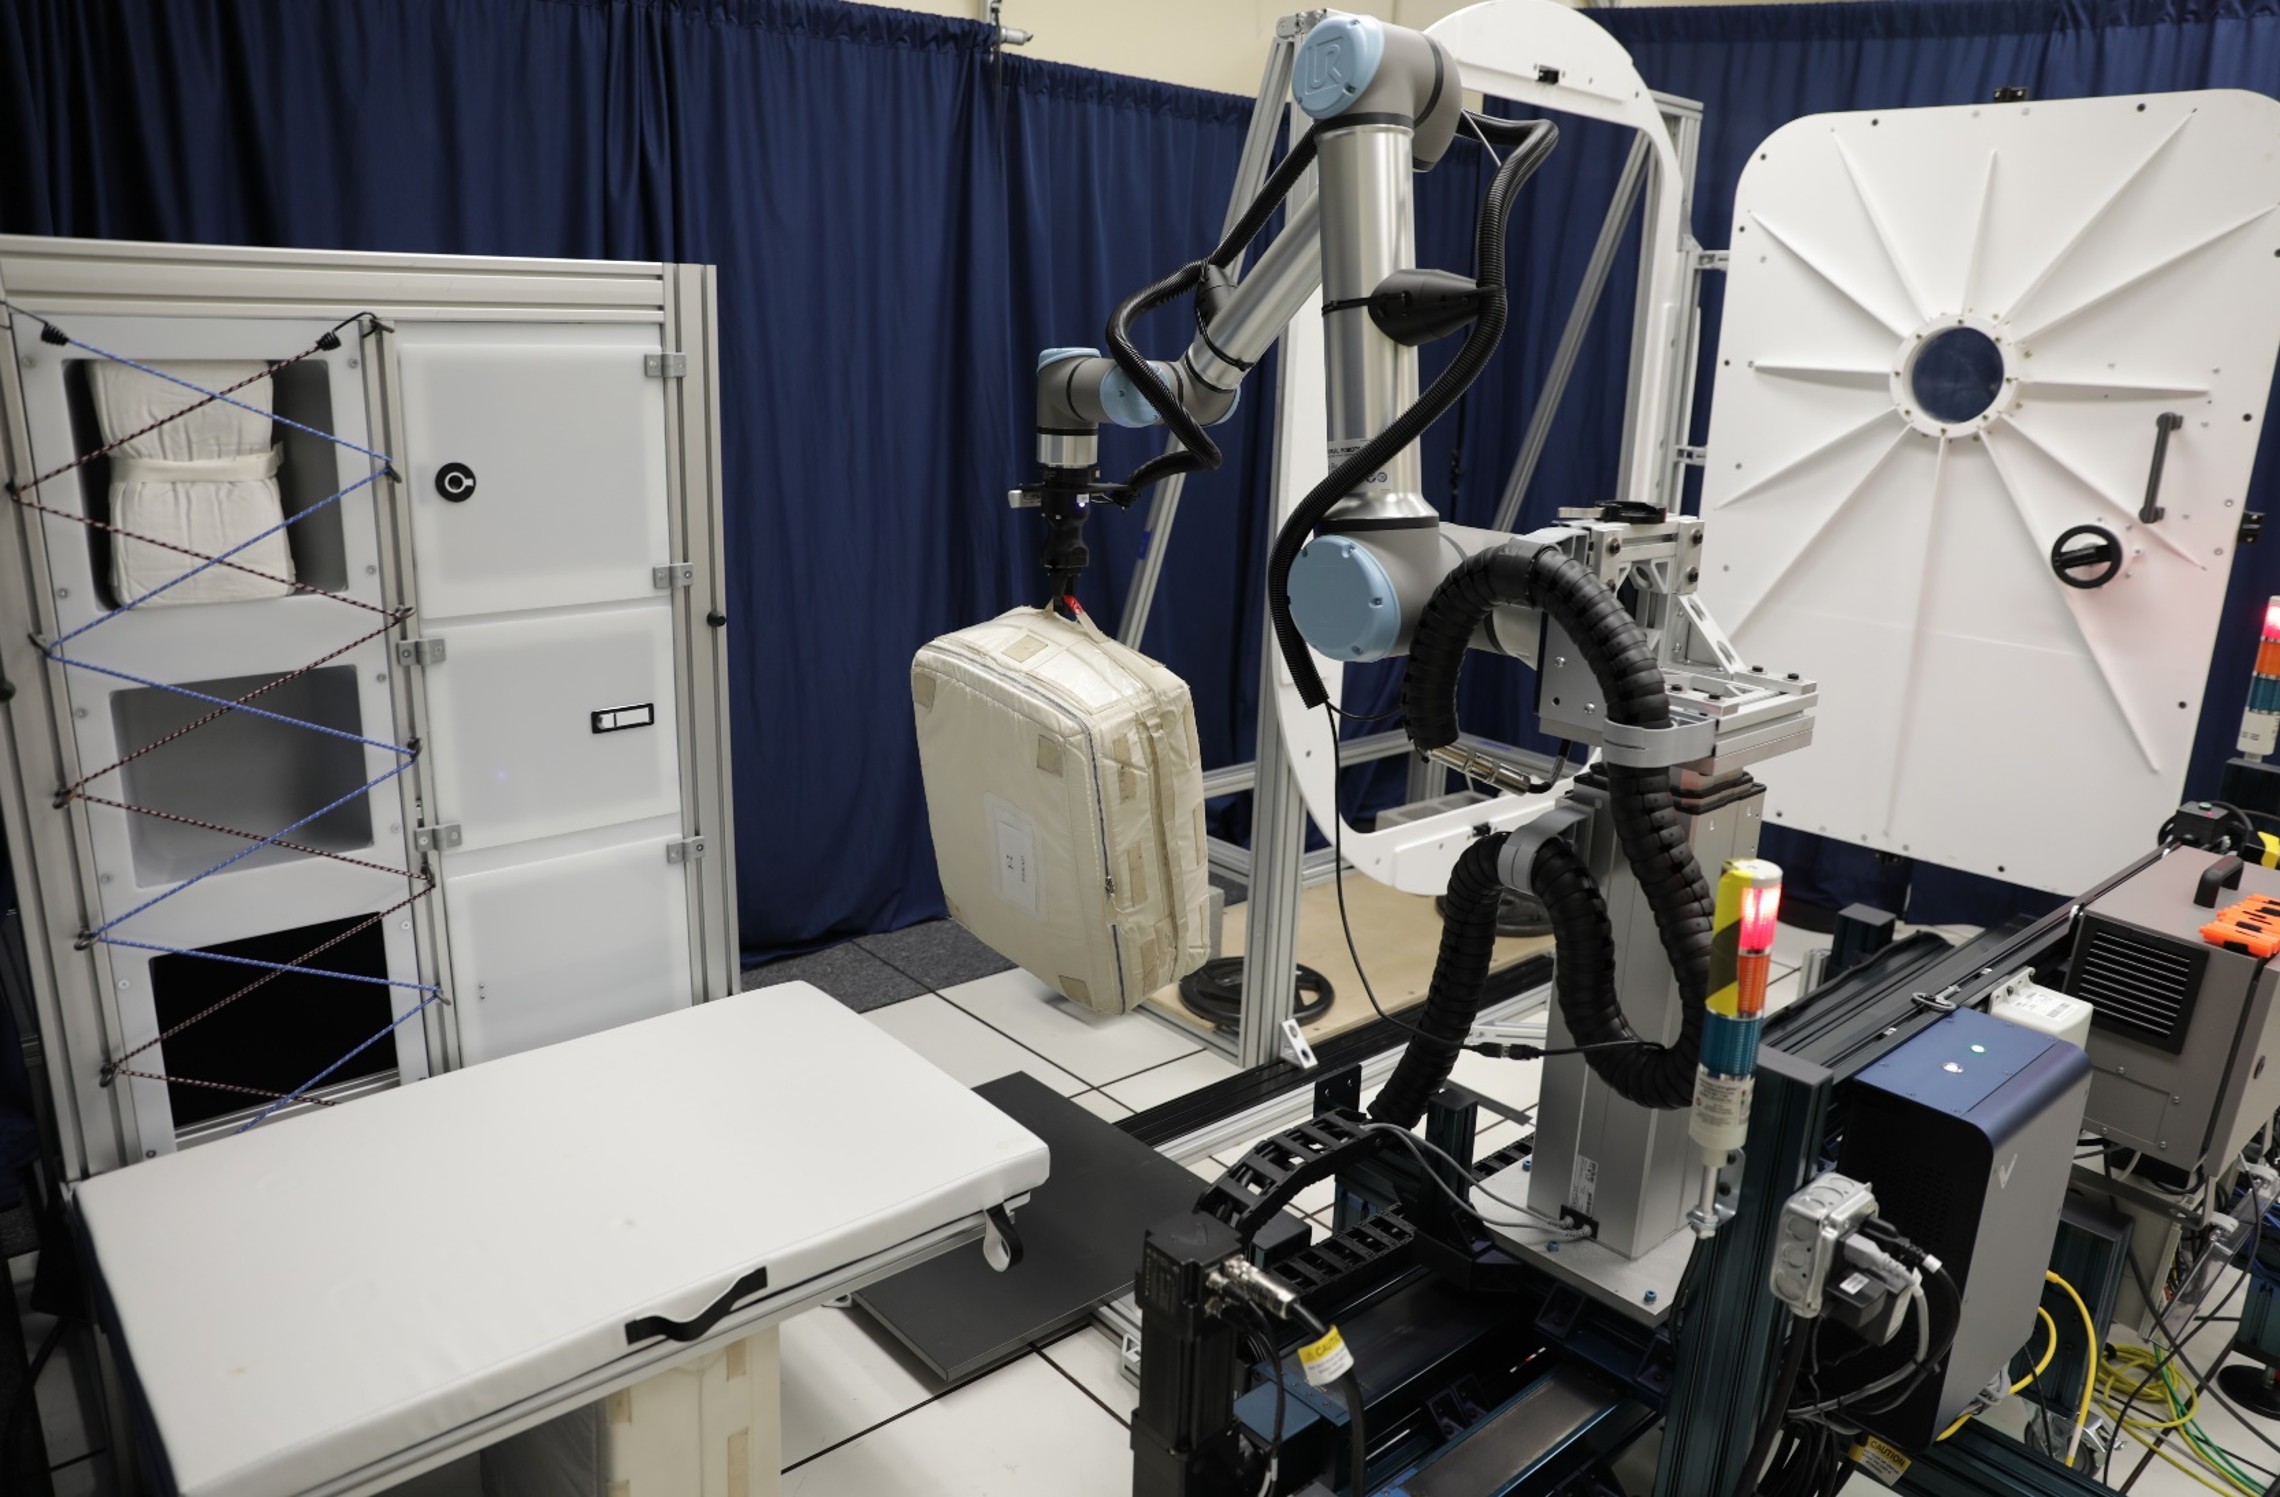
Azimi acknowledged the team’s near-term emphasis on technologies that can support a sustained human presence on the lunar surface but noted those technologies also have applications for future missions to Mars. In fact, the team is collaborating with other agency organizations on a forthcoming NASA challenge that will invite the public to share their ideas for technology solutions for Mars exploration.
Azimi said he is often asked why there is a robotics team at Johnson. “It’s really about the human elements – either working in environments designed for humans or working alongside humans. That’s our niche,” he said. “We’re uniquely positioned to bring in folks who are designing the human environments.”
Explore More
Source: www.nasa.gov